TOIO AGENTS
How can multi-agent behavior become observable, physically situated, and open to correction?
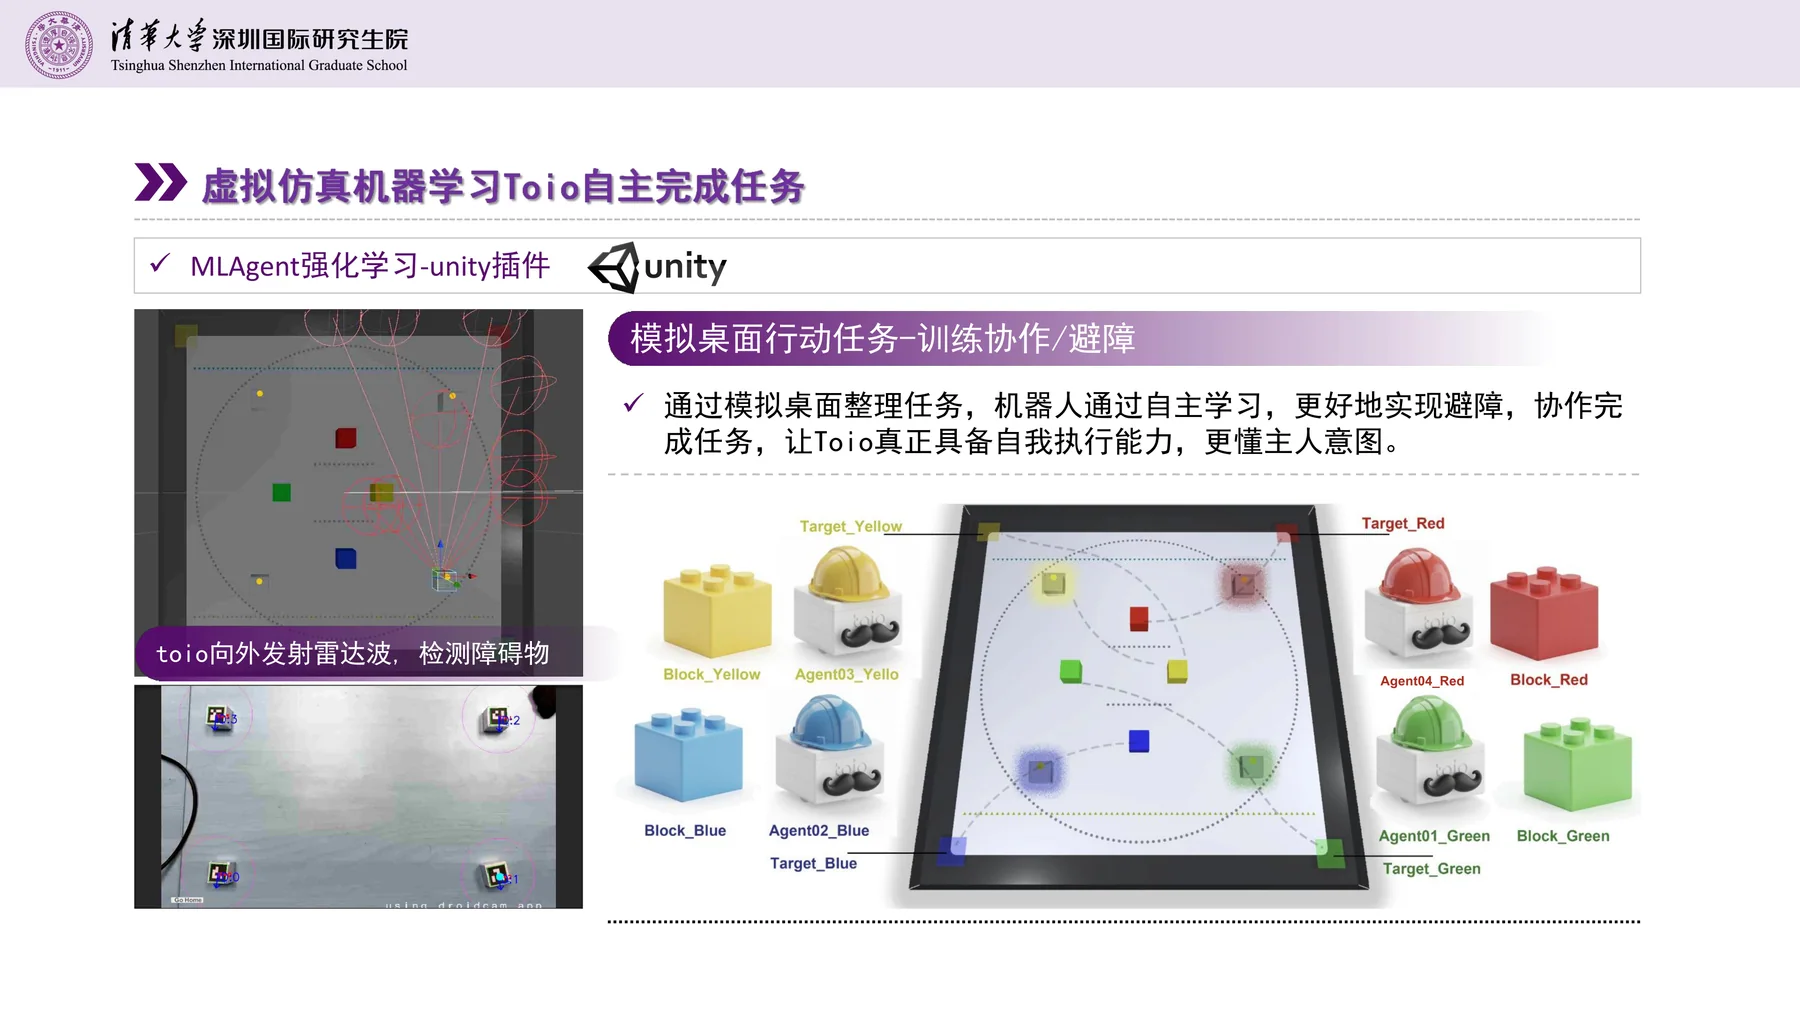
A Unity-to-physical testbed connecting multi-agent training, overhead localization, BLE control, and tabletop robots.
- ROLE
- System and experiment development
- STATUS
- EXPERIMENT / ACTIVE
COMPLETE PROJECT RECORD
Every available drawing, image, and process record is kept in sequence. Nothing is cropped into a decorative slideshow.
The tabletop task makes multi-agent behavior directly observable.
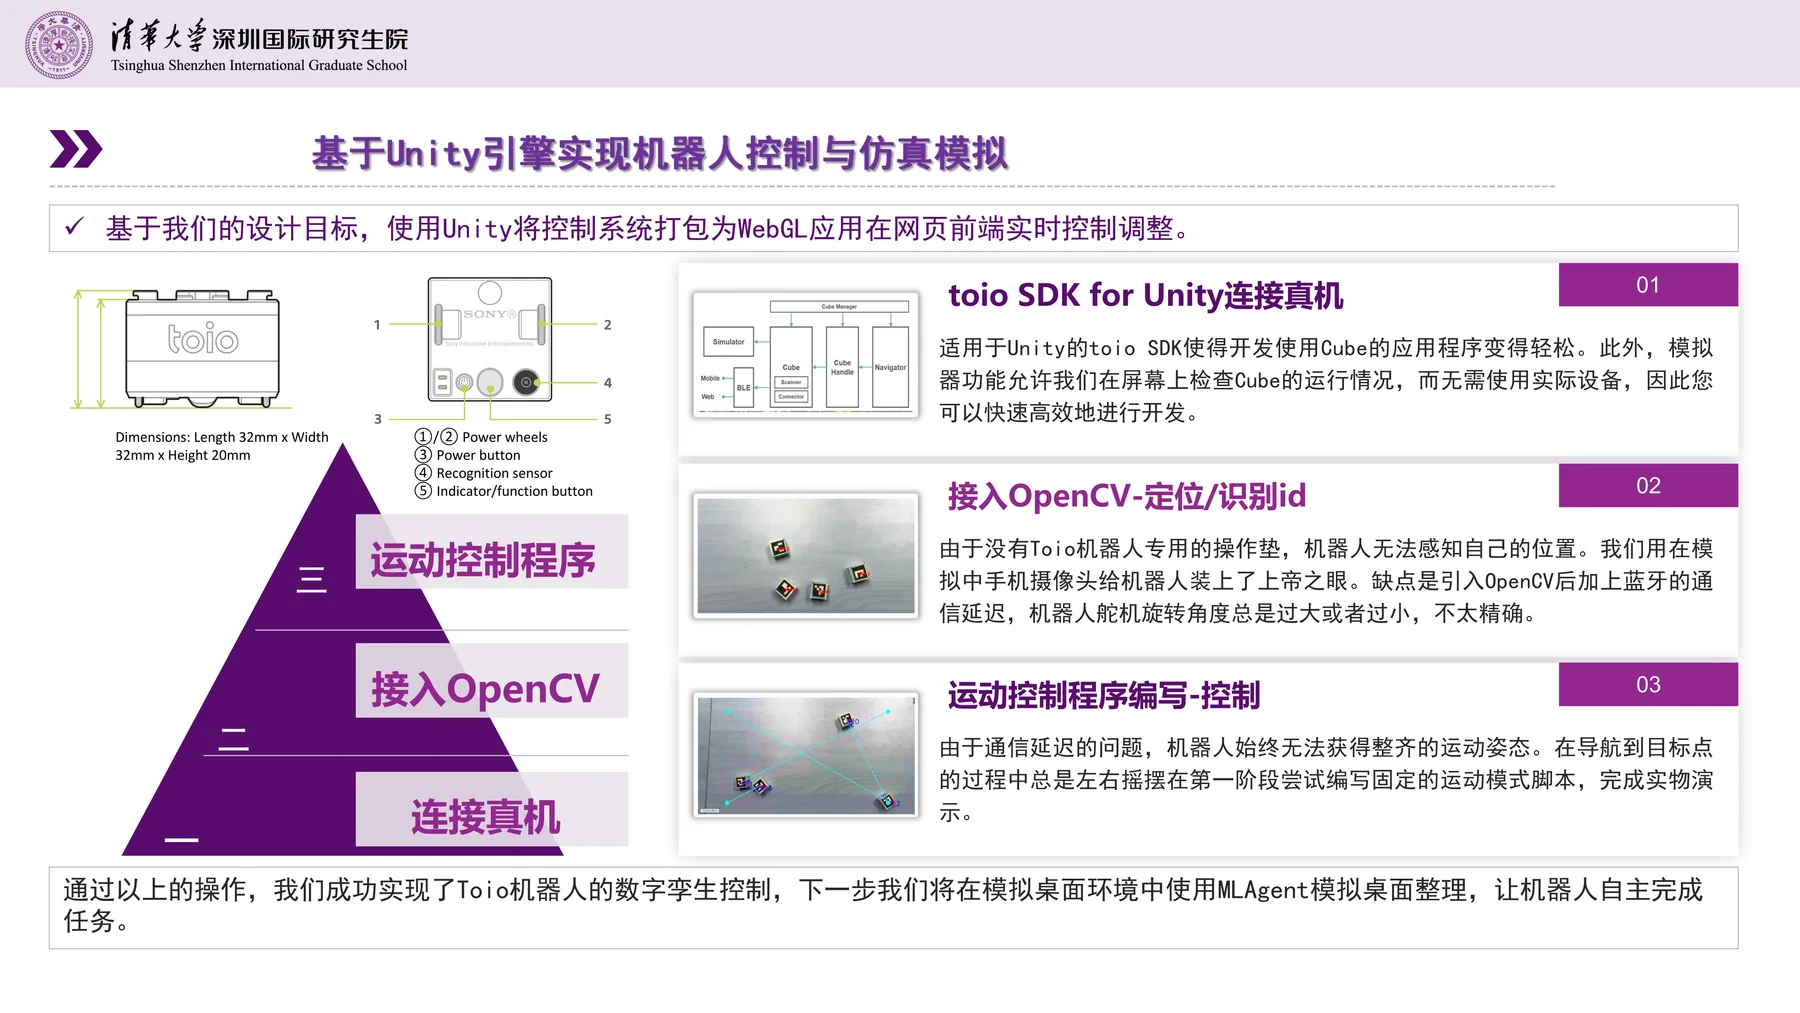
The diagram separates training, localization, communication, and physical actuation.
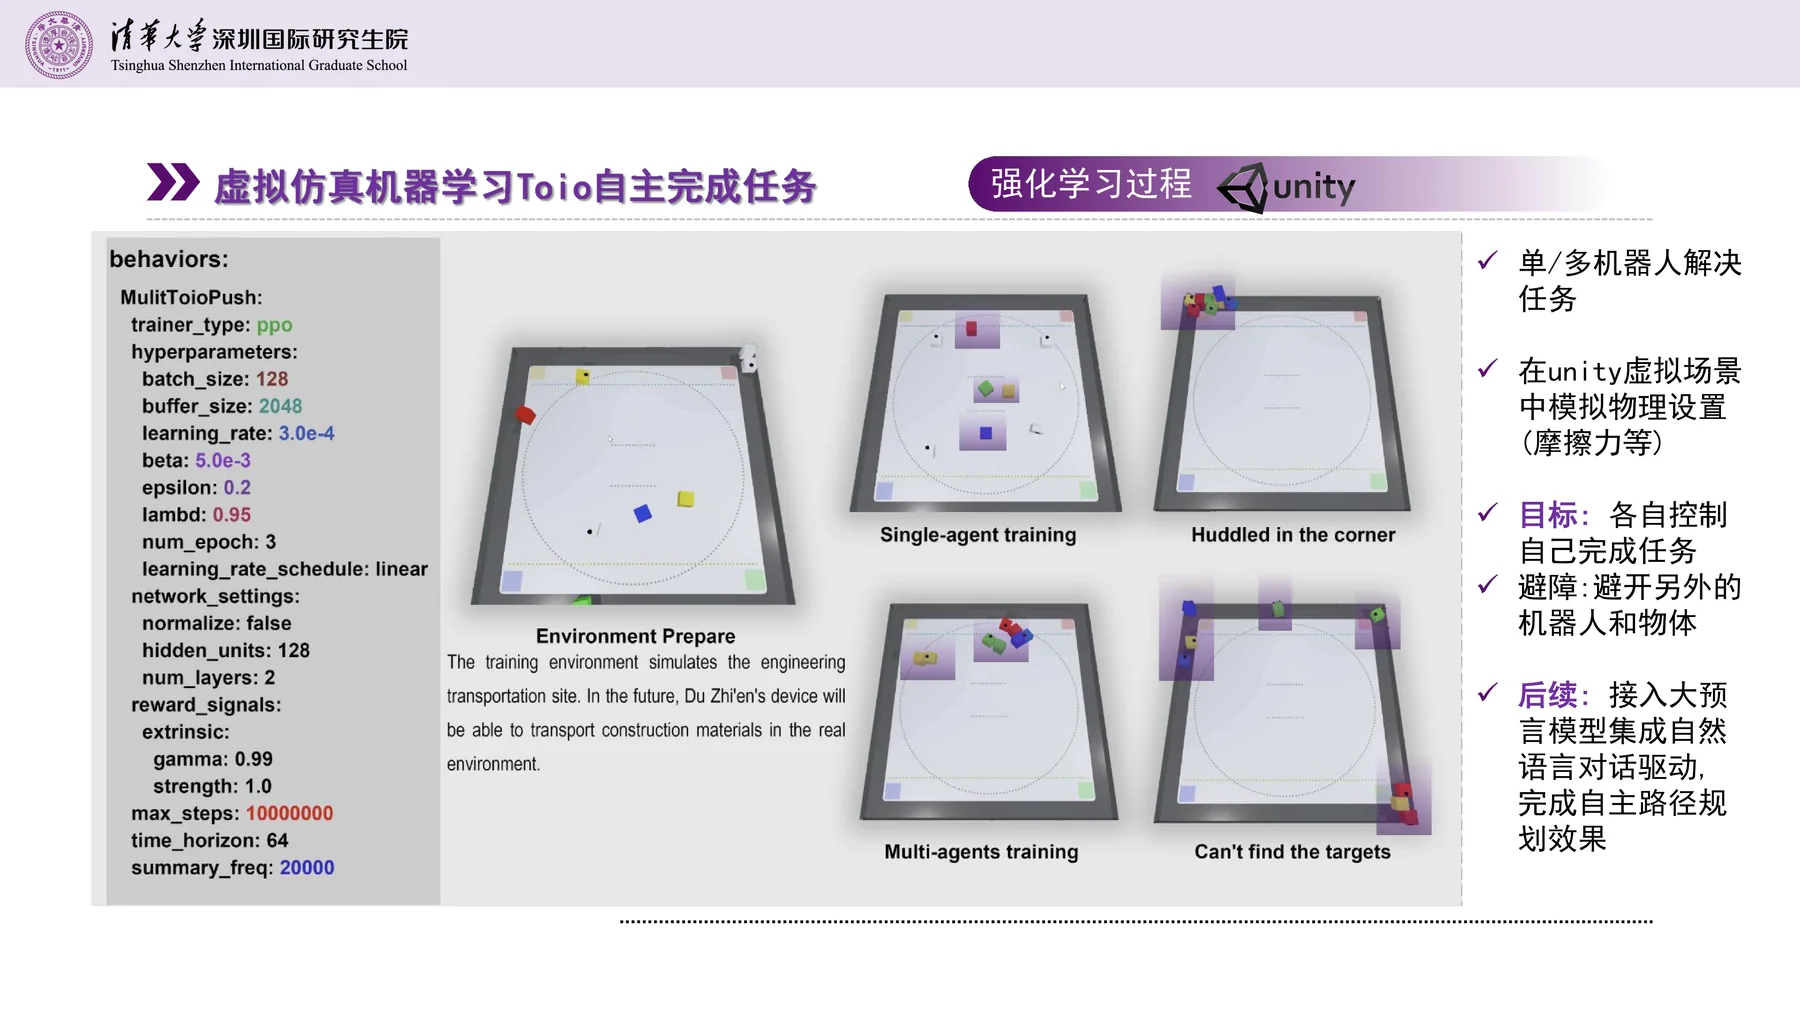
Simulation training is presented as process evidence rather than final transfer performance.
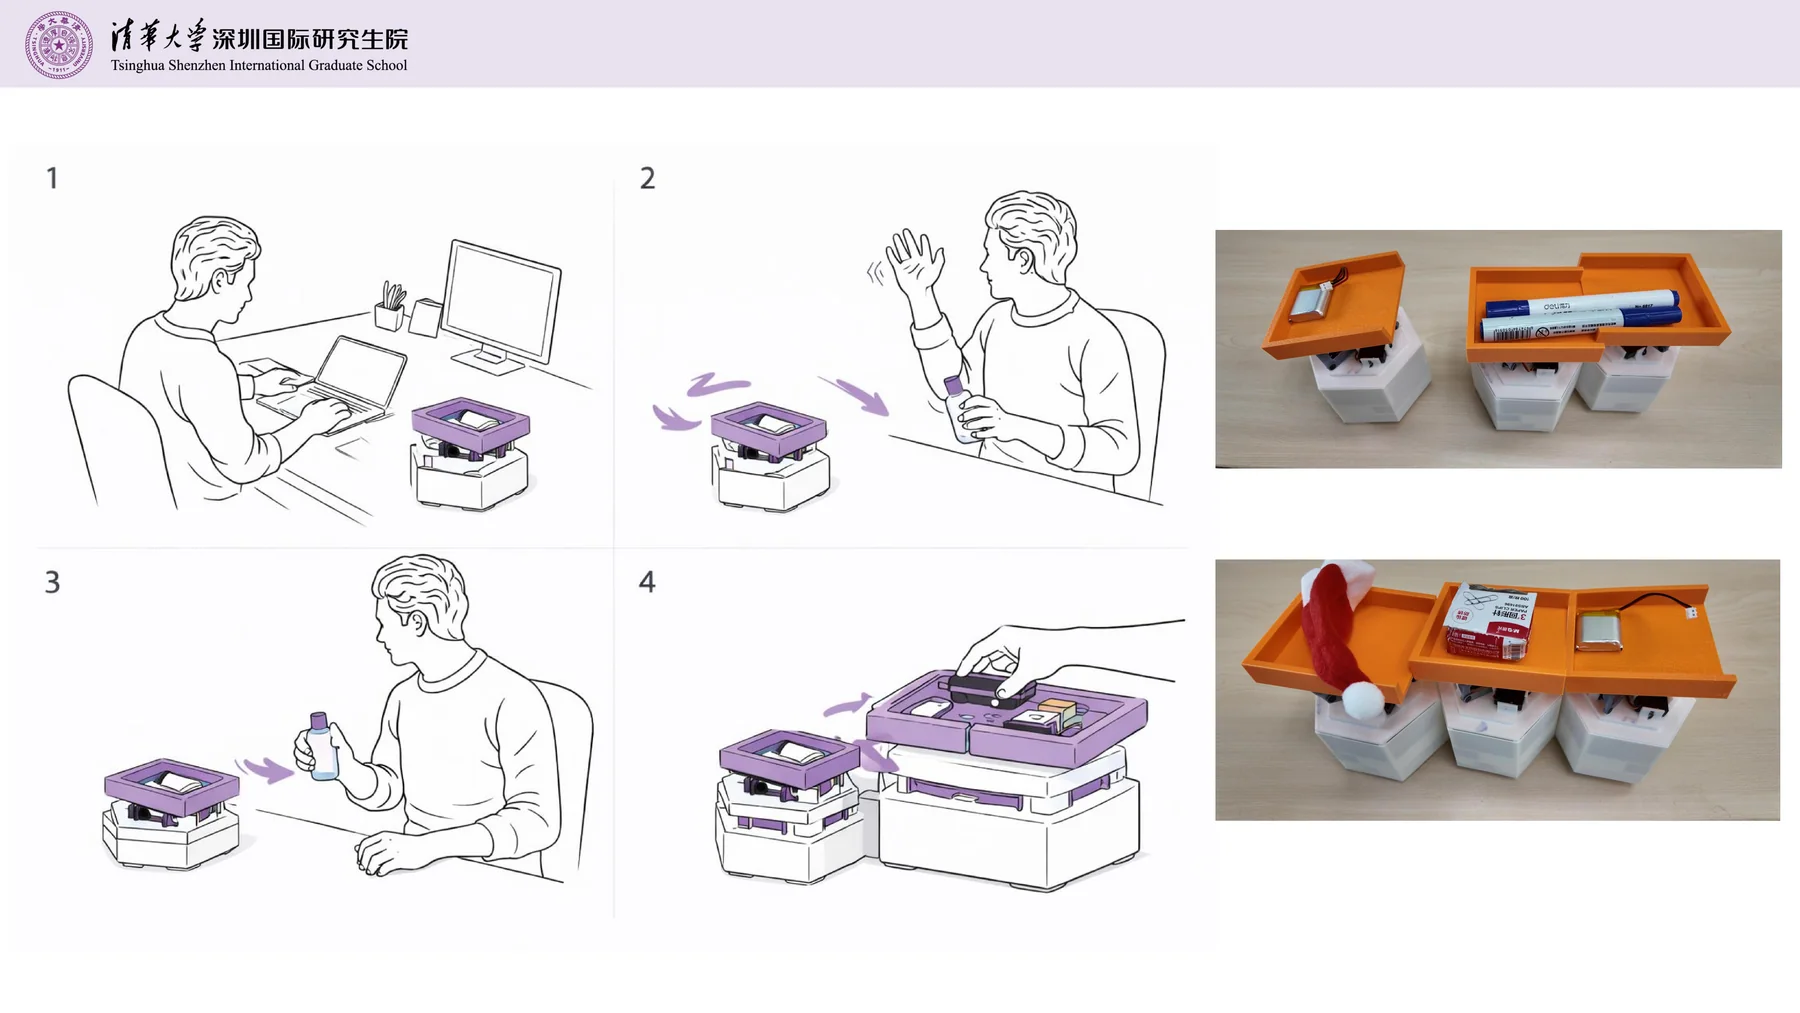
A carrying task records one embodied cooperation scenario.
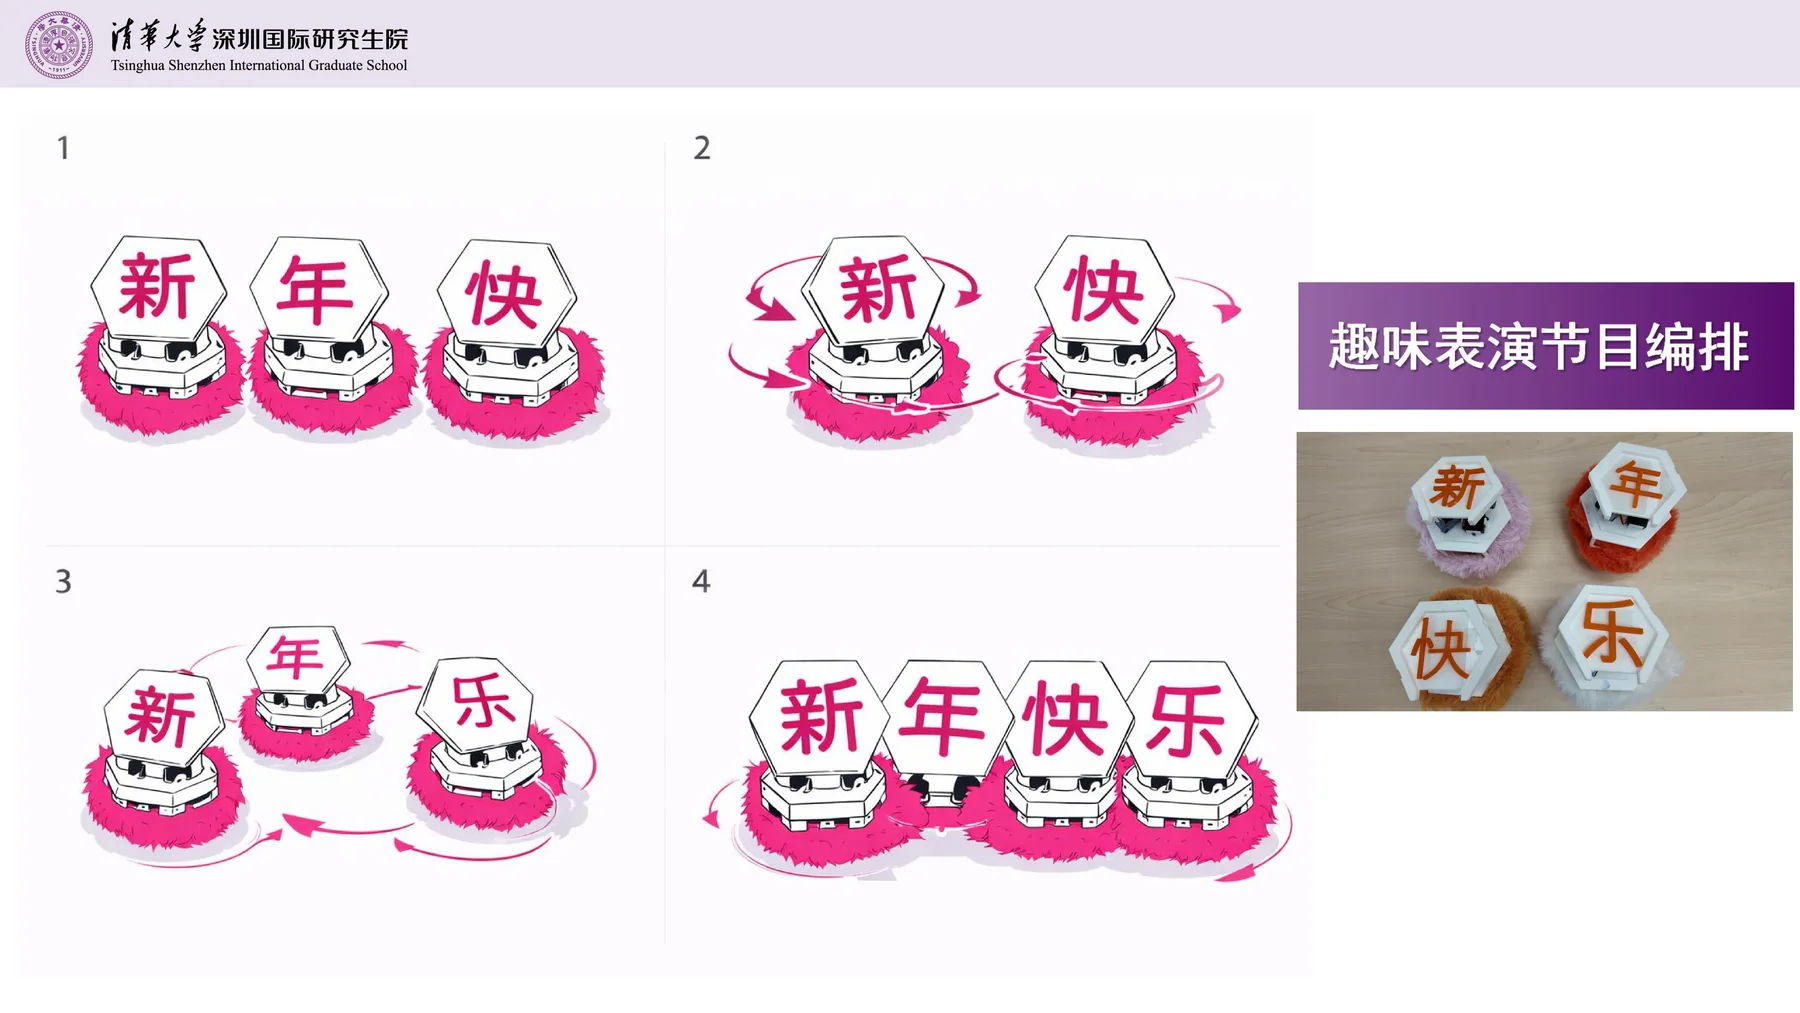
A second scenario tests coordination through visible movement.
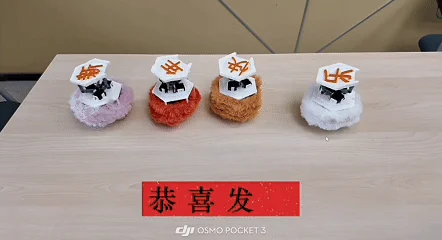
The still frame identifies the public demonstration record.
The recording preserves observable physical behavior of the implemented controller.