B.03 / Robotic assembly · 2026
MECHANICAL LATTICE
One module. A sequence. An open system.
ROBOTIC PROTOTYPE
01 / THE MODULE
A connection becomes a module.
A flat joint becomes a repeatable volume. The gripper helps shape its geometry.
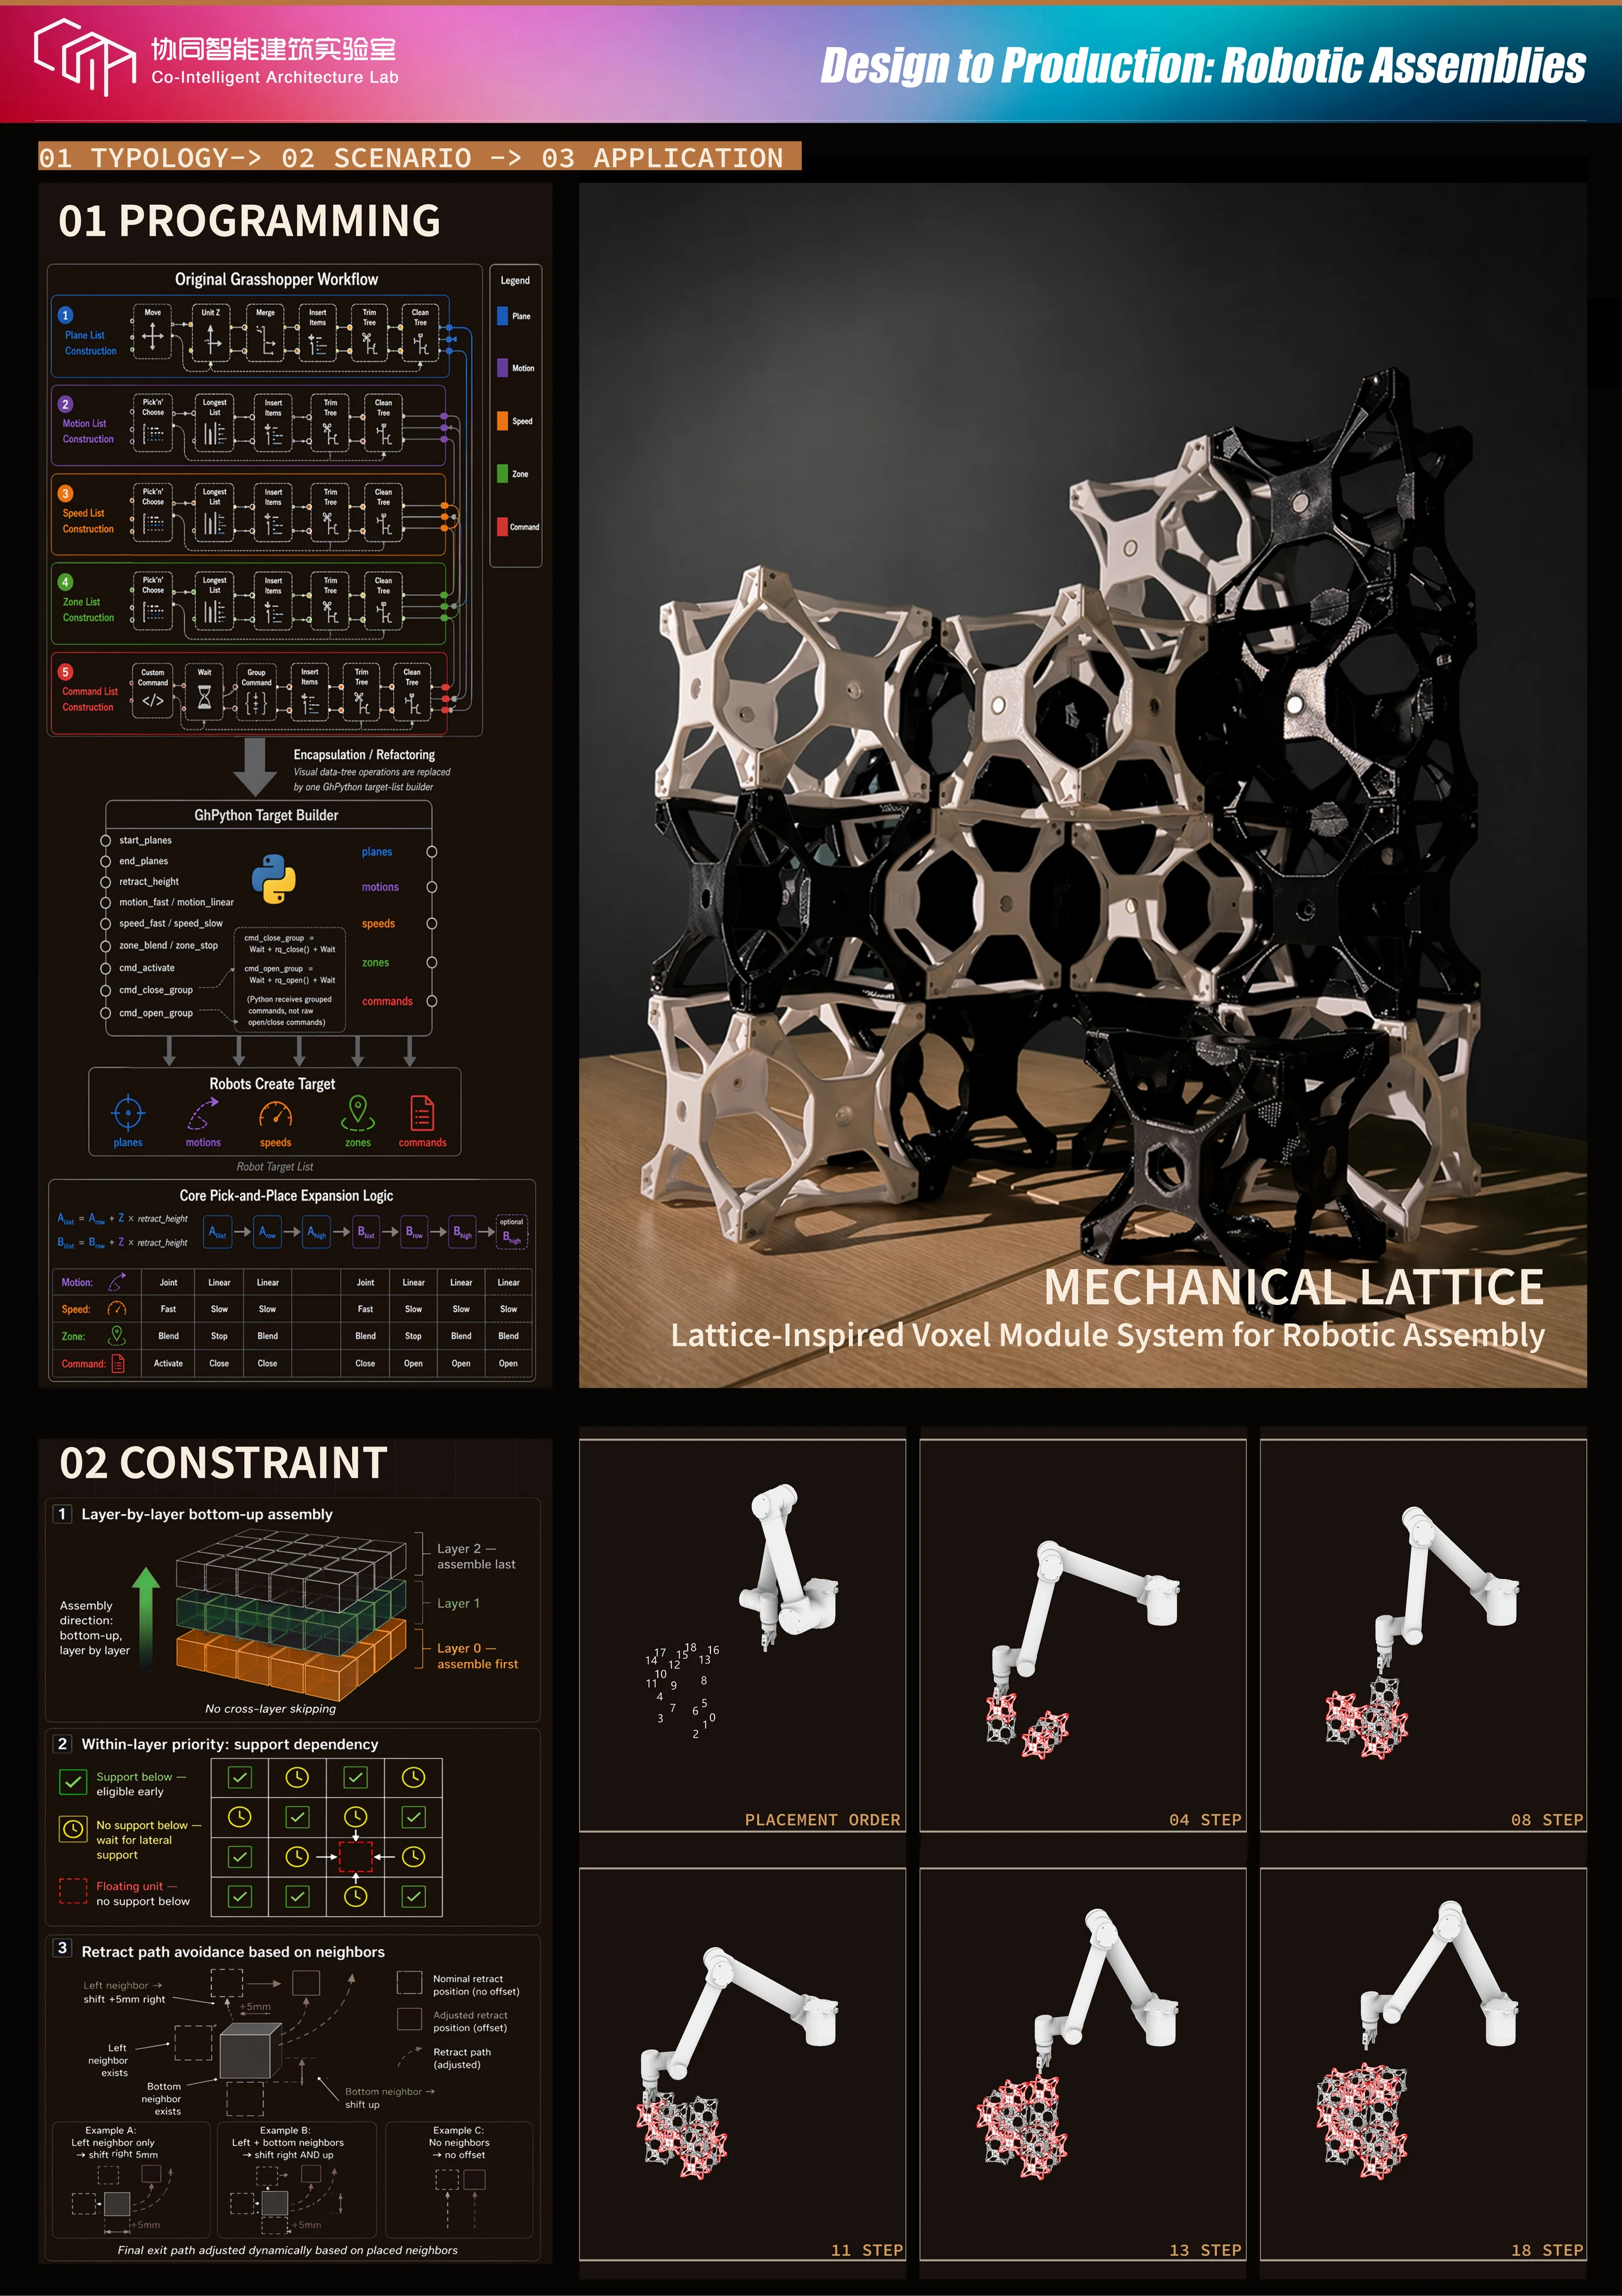
02 / THE INSTRUCTIONS
Give geometry a sequence.
Planes, motion, speed, zones, and gripper commands become a coordinated target list.
03 / THE ASSEMBLY
One placement at a time.
Build from below, retain support, and leave a path for the arm to retreat.
04 / IN MOTION
From the target to the table.
Recorded robotic placement at prototype scale.
05 / SPATIAL POSSIBILITIES
The same unit. Different spaces.
Terrace, threshold, shelter: architectural scenarios for an evolving module system.
Porous gateway
Canopy shelter
A system that stays open.
Prototype assembly is documented. Architectural scenarios remain speculative; structural performance is not established by these images.
Co-Intelligent Architecture Lab
Ren Yuxin · Qiami Ku · Sirui Hu